 |
|
Loading...
Searching...
No Matches
|
|
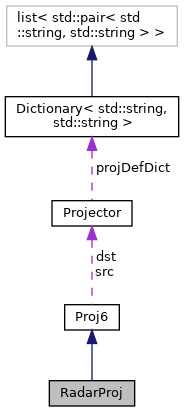
Public Member Functions | |
| RadarProj (double lonDeg=0.0, double latDeg=0.0) | |
| Sets location of the radar and the azimuthal equidistant (AEQD) projection accordingly. | |
| void | setSiteLocationDeg (double lon, double lat) |
| Sets location of the radar and the azimuthal equidistant (AEQD) projection accordingly. | |
| void | setSiteLocationRad (double lon, double lat) |
| Sets location of the radar and the azimuthal equidistant (AEQD) projection accordingly. | |
| void | getBoundingBox (double range, double &lonLL, double &latLL, double &lonUR, double &latUR) const |
| Bounding box in radians. | |
| void | getBoundingBoxDeg (double range, double &lonLL, double &latLL, double &lonUR, double &latUR) const |
| Bounding box in degrees. | |
| void | setLatLonProjection () |
| void | determineBoundingBoxM (double range, double &xLL, double &yLL, double &xUR, double &yUR) const |
| Given radar's range, returns the metric bounding box using the current projection. | |
| void | determineBoundingBoxM (double range, drain::Rectangle< double > &bbox) const |
| Given radar's range, returns the metric bounding box using the current projection. | |
 Public Member Functions inherited from Proj6 | |
| Proj6 (const Proj6 &p) | |
| template<typename ... T> | |
| void | setProjectionSrc (const T &...args) |
| Sets source projection. | |
| void | setProjectionSrc (const Projector &projDef) |
| Sets source projection, primarily using EPSG code. | |
| template<typename ... T> | |
| void | setProjectionDst (const T &...args) |
| Sets destination projection. | |
| void | setProjectionDst (const Projector &projDef) |
| Sets destination projection, primarily using EPSG code. | |
| void | setProjections (const std::string &projDefSrc, const std::string &projDefDst) |
| Sets source and destination projection. TOOD: EPSG code handling. | |
| const std::string & | getProjStrSrc () const |
| Returns the projection std::string applied by the last setProjection call. | |
| const std::string & | getProjStrDst () const |
| const Projector & | getSrc () const |
| const Projector & | getDst () const |
| void | projectFwd (double &x, double &y) const |
| Forward projection (in-place) | |
| void | projectFwd (double x, double y, double &x2, double &y2) const |
| Forward projection. | |
| void | projectFwd (drain::Point2D< double > &point) const |
| Forward projection. Example implementation of project<>() . | |
| void | projectFwd (const drain::Point2D< double > &point, drain::Point2D< double > &point2) const |
| Forward projection. Example implementation of project<>() . | |
| void | projectInv (double &x, double &y) const |
| void | projectInv (double x, double y, double &x2, double &y2) const |
| void | projectInv (drain::Point2D< double > &point) const |
| void | projectInv (const drain::Point2D< double > &point, drain::Point2D< double > &point2) const |
| Forward projection. Example implementation of project<>() . | |
| void | debug (std::ostream &ostr=std::cout, int wkt=-1) |
| bool | isLongLat () const |
| Check if destination projection is longitude-latitude degrees. | |
| bool | isSet () const |
| std::string | getErrorString () const |
Additional Inherited Members | |
| Static Public Member Functions inherited from Proj6 | |
| static const std::string & | getProjVersion () |
| Public Attributes inherited from Proj6 | |
| Projector | src |
| Projector | dst |
| Protected Member Functions inherited from Proj6 | |
| void | setDirectMapping (bool lenient) |
| Set crs_to_crs projection, if both src and dst projections are set. | |
| template<PJ_DIRECTION D, class POINT_XY > | |
| void | project (POINT_XY &point) const |
| template<PJ_DIRECTION D> | |
| void | project (double &x, double &y) const |
| Protected Attributes inherited from Proj6 | |
| PJ_CONTEXT * | pjContext = nullptr |
| Detect EPSG code from "+init=epsg:EPSG" argument. | |
| PJ * | proj = nullptr |
| void determineBoundingBoxM | ( | double | range, |
| double & | xLL, | ||
| double & | yLL, | ||
| double & | xUR, | ||
| double & | yUR | ||
| ) | const |
Given radar's range, returns the metric bounding box using the current projection.
Map AEQD => target (composite)
Sets location of the radar and the azimuthal equidistant (AEQD) projection accordingly.
Sets location of the radar and the azimuthal equidistant (AEQD) projection accordingly.
 1.9.8